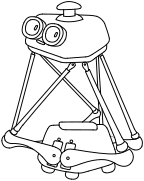
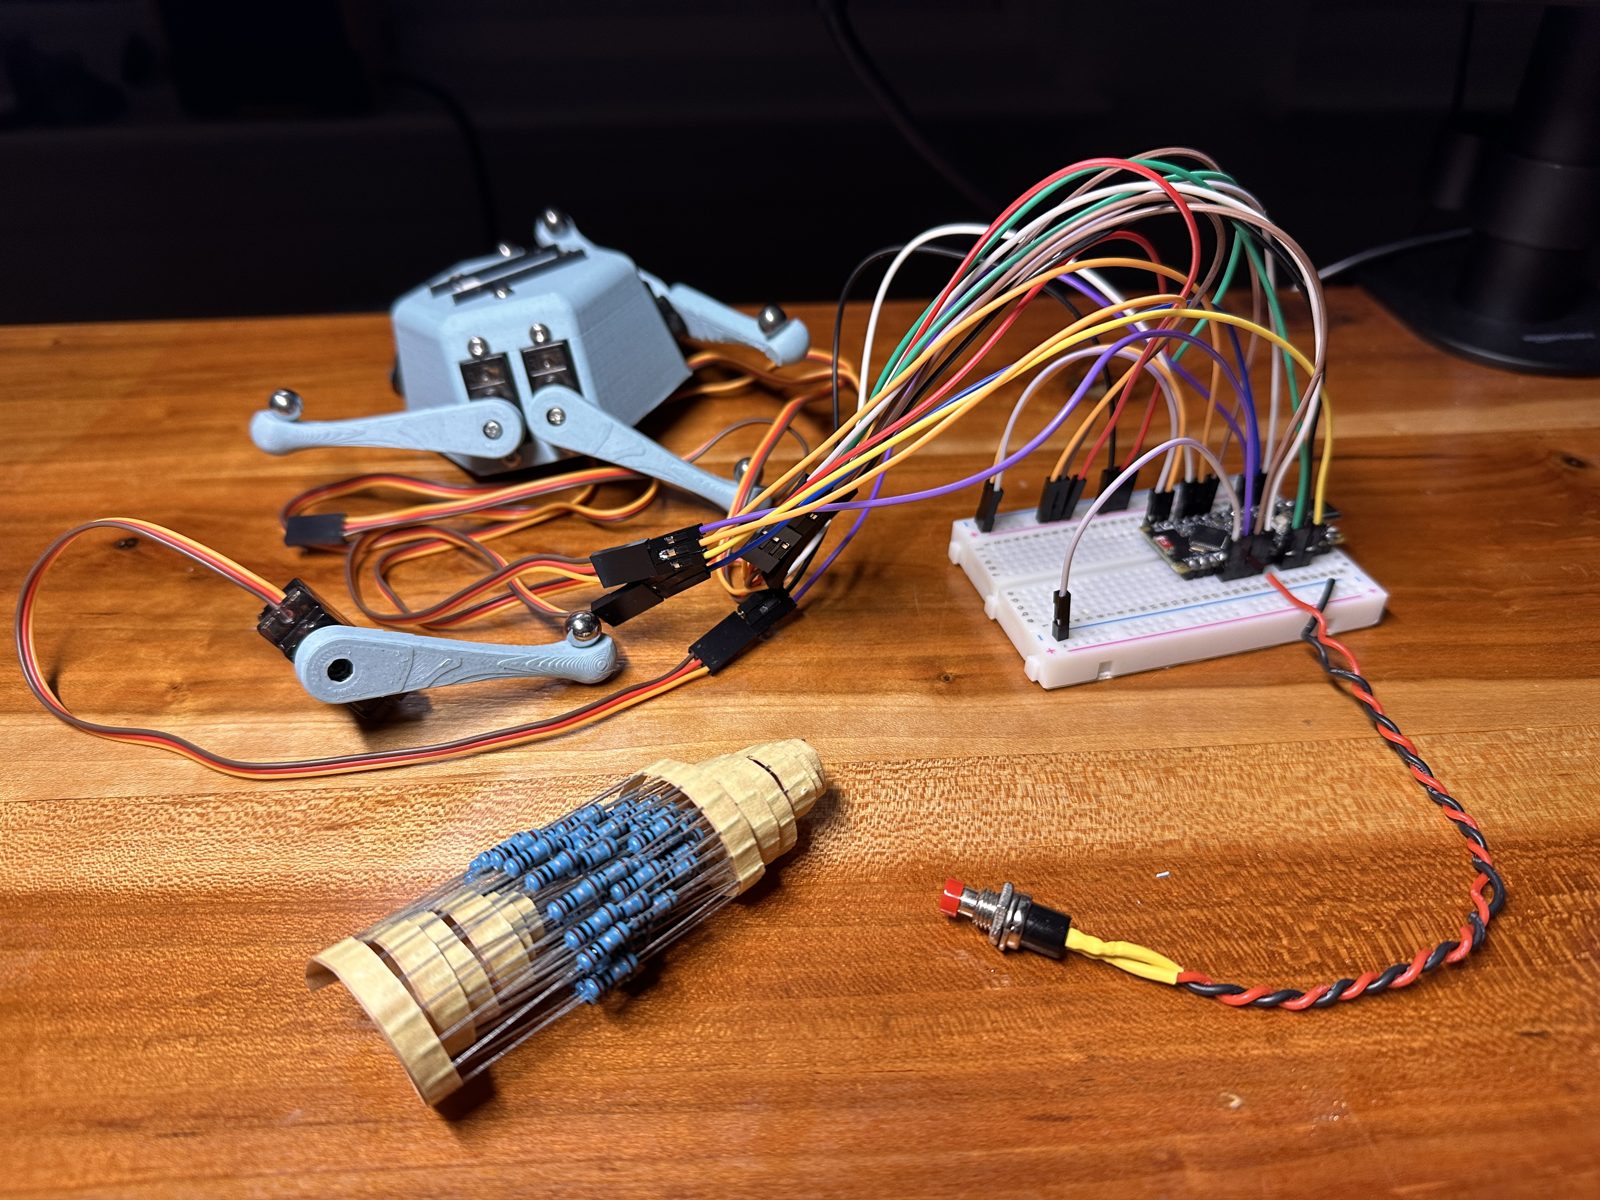
Right now I'm working on adding a lot of functionality to Stewy for just a few cents in components. The idea is to add current sensing to the existing servo motors. One extra resistor per servo so that Stewy can "feel" the forces going through each motor.
The first thing I'm using this for is auto-homing the arms. Instead of manually dialing in offsets every time the robot is assembled, Stewy will just tap its feet on the ground to figure out where they are. When the motor hits the floor, the current will spike, and we can set the offset based on that angle.
I'm hoping this works out well, because I think it could eventually be used to improve Stewy's walking ability. Just an idea at this point, but I think Stewy being able to feel the forces in each arm could help it adapt its walking pattern to different terrains.
· Hardware
Print Files Available Now!
This morning I've put a download button on the 3d printing page for the .3MF print files. Hopefully this makes printing and building Stewy a bit easier.
I think a good next step is to add links to download and access everything in a section on the home page.
· Devlog
How to do documentation
What is the right form of documentation?
I've finished up the website over the past few days and I'm not sure how in depth I should make the documentation or if written documentation is the best method for showing how Stewy works.
In the past when I started out by following other people's projects, super in depth technical documentation was quite overwhelming. I'm not quite sure how in depth I should go or really what the best format is. Personally, I've learned best by following long form videos where I write the code and build the robot as the instructor does it.
For now, I think I'll stick with the high level descriptions of each file in the documentation page, then run a poll after Stewy's release for what form future documentation should come in. Do people want technical written documentation, written guides, video guides, short form, long form? I think the right choice is getting Stewy out there and asking for your opinion.
· Devlog
3/22/26 yesterday went well
Testing the 10 robots yesterday went much better than expected. Going into it I had already found one head assembly that didn't work so I didn't have high hopes. It turned out that was the only one that didn't work though, and swapping out its microcontroller fixed it.
The only other problem I found was that some of the joysticks are drifting and need larger dead zones. This should be an easy fix; it just needs a variable at the top of Stewy.ino for tuning it.
The goal for today is to fix that problem and get the rest of the photos and videos I need for Stewy V2's release.
To do today:
Implement and test the dead zone variable
write down all the photos I want for the site
· Devlog
3/21/26 First Post
For at least the last 6 months I've been working on improving my robot Stewy, and now I'm nearing the milestone of releasing a new YouTube video that introduces version 2 of the robot. My current goal is to do this by end of March.